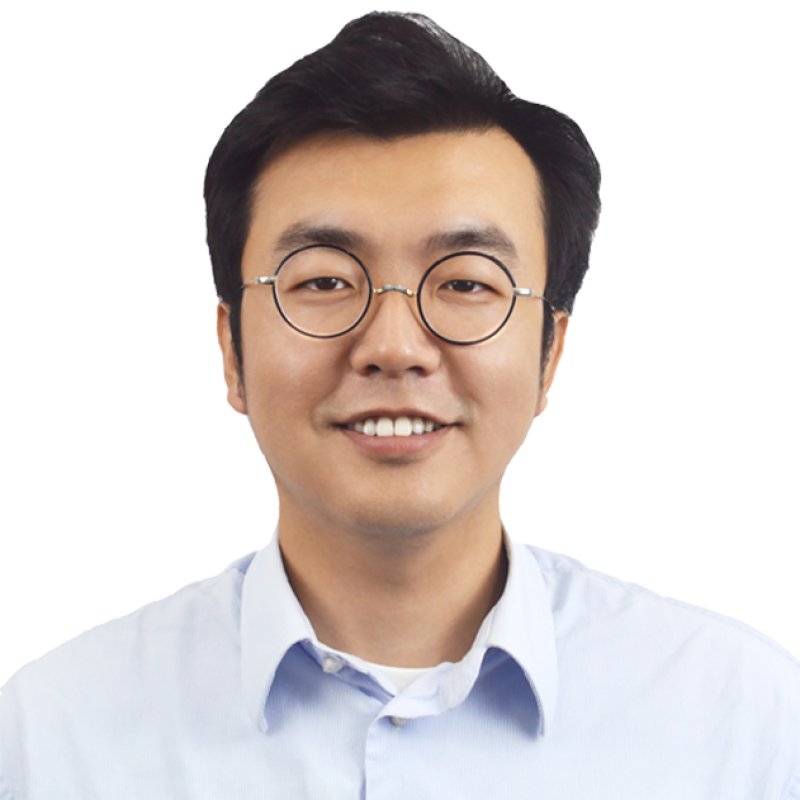
Professor Xiaoqiang JI earned his Ph.D. from Columbia University, USA. He is currently Assistant Professor and Ph.D. Supervisor at The Chinese University of Hong Kong, Shenzhen. He also serves as Deputy Director of the Embodied Intelligence Center at the Shenzhen Institute of Artificial Intelligence and Robotics for Society, Deputy Director of the Guangdong Provincial Innovation Center, Engineering Technology Research Center and Engineering Research Center for Embodied Intelligent Robots, Committee Member of the Intelligent Internet�of�Things Special Committee under the China Simulation Federation, and Principal Scientist of the ASEAN�China Artificial Intelligence Laboratory.
His research focuses primarily on artificial intelligence control systems. He has presided over numerous scientific research and talent programs, including the Frontier Exploration Project in Data Science and Artificial Intelligence of the National Natural Science Foundation of China, General Program of Guangdong Province, and major research projects of Shenzhen Municipality. To date, he has published more than sixty papers and one monograph in top�tier international journals and conferences such as IEEE Transactions on Automatic Control (TAC), Automatica, Journal of Field Robotics (JFR), ACM Transactions on Cyber�Physical Systems (ACM T�CPS), IEEE/ASME Transactions on Mechatronics, IEEE Transactions on Automation Science and Engineering (T�ASE), IEEE Robotics and Automation Letters (RA�L), CDC, and ICRA. Notably, he is one of the global advocates for learning control design for non�minimum�phase systems. He acts as a reviewer for multiple premier journals and conferences including IEEE�TAC, Associate Editor of MECC, Youth Editorial Board Member for Robot Learning, and Track Chair for international conferences such as RCAR. He has recently received several awards including the CINT Outstanding Paper Award, the ISUI Best Paper Award, and the Wiley China High�Contribution Author Award.
Led by Professor JI, the AI-driven Control and Decision Laboratory is an interdisciplinary platform, which requires deep integration of basic sciences such as control theory, artificial intelligence, robotics, high-performance computing, big data, etc. It is committed to conducting research on basic theories and original innovations in the field of artificial intelligence and intelligent systems.
Academic area (no more than three):
- Artificial Intelligence and Robotics
- Computer Engineering
- Electrical Engineering
- Chemistry
- Mathematics and Applied Mathematics
- Materials
- New Energy Science and Engineering
- Physics
Personal Website:
https://cnd-lab.github.io/
专著:
· Xiaoqiang Ji, Y. Chen, Y. Chen, and S. Liu. Embodied�Intelligent Dexterous Hand Manipulation (in Chinese), PHEI 电子工业出书社.
Research Paper: (*Correspondence author)
- Xiaoqiang Ji*, Y. Dou, S. Zhu and Y. Xu. Unified feedforward control framework for disturbed nonminimum phase systems: the Koopman-type inverse operator approach. IEEE Transactions on Automatic Control, vol. 71, no. 7, pp. 4858-4864, July 2026.
- Z. Lin, Z.Wei, Y.Zhong, N. Ding Y.Zhao and Xiaoqiang Ji*. ALICE: Autonomous lifelong intelligence framework for cross-embodiment via continuous internal states feedback mechanism. Future Generation Computer Systems, vol 186, Jan. 2027, 108730.
- H.Yu, S.Zhu, Z.Sun and Xiaoqiang Ji*. Online stable inversion of non-minimum phase systems with guaranteed stability via terminal-constrained MPC. IEEE 65th Conference on Decision and Control (CDC), 2026, accepted.
- S. Zhu, Xiaoqiang Ji*, R. Longman, and Y. Xu. Presicion tracking for non-minimum phase LPTV systems via a lifted time stable inversion. IEEE Transactions on Automatic Control, 10.1109, pp. 1-8, 2025.
- H.Wan, Y.Zhang, J.Wang, D.Wu, M.Li, X.Chen, Y.Deng, Y.Huang, Z.Sun, L. Zhang and Xiaoqiang Ji*. Toward universal embodied planning in scalable heterogeneous collaboration and control, Journal of Field Robotics (JFR), 1556-4959, 2025.
- Xiaoqiang Ji*, S. Zhu, Y. Xu, and R. Longman. Lifted time stable inversion based feedforward control for linear non-minimum phase systems, Automatica, vol. 171, pp. 111979, 2025 .
- H.Wan, J.Cheng, Y.Deng, D.Wu, Y.Chen, Z.Lin, J.Liu, J.Yu and Xiaoqiang Ji*. Towards physics aware embodied control with grapth based object-centric learning, ACM Transactions on Cyber-Physical Systems, Sep 2025.
- H.Wan, Y.Chen, Y.Deng, Z.Wei, D.Li, Z.Lin, D.Wu, J.Cheng, and Xiaoqiang Ji*. EmbodiedAgent: A scalable hierarchical approach to overcome practical challenge in multi-robot control, 2025 IEEE/RSJ Internaitonal Conference on Intelligent Robots and Systems (IROS), accepted, 2025.
- S.Zhu, Xiaoqiang Ji*, R. Longman, and Y. Xu. Lifted time stable inversion based high precision feedforward control for non-minimum phase systems, IEEE 63rd Conference on Decision and Control (CDC), December 16-19, 2024.
- Xiaoqiang Ji, X.Zhang, S.Zhu, F.Deng and B.Zhu. Data-driven adaptive consensus control for heterogeneous nonlinear multi-agent systems using online reinforcement learning, Neurocomputing, Vol. 596, 127818, 2024.
- J.Li, C.Zhao, Xiaoqiang Ji*, M.Li, G.Lu, Y.Xu, and D.Zhang. Multi-view instance attention fusion network for classification, Information Fusion, Vol. 101, 101974, 2024.
- K.Xue, Xiaoqiang Ji*, D.Qu, Y.Peng and H.Qian*. Oboat: An agile omnidirectional robotic platform for unmanned surface vehicle tasks, IEEE/ASME Transactions on Mechatronics (T-Mech), vol.28, no.5, pp.2413-2424, Oct. 2023.
- S. Zhu, Y. Wang, B. Zhu, and Xiaoqiang Ji*. Tracking error boundary of novel stable inversion based feedforward control for a class of non-minimum phase systems, CINT, vol 1714, Springer, 2023. [ Excellent Paper Award]
- K.Xue, C.Ren, Xiaoqiang Ji*, and H. Qian*. Design, modeling and implementation of a projectile-based mechanism for USVs charging tacks, IEEE Robotics and Automation Letters (RA-L),vol. 8, no. 1, pp. 360-367, Jan. 2023.
- K.Xue, J. Liu, N. Xiao, Xiaoqiang Ji*, and H. Qian*. A bio-inspired simultaneous surface and underwater risk assessment method based on stereo vision for USVs in nearshore clean waters, IEEE Robotics and Automation Letters (RA-L), 2022.
- Xiaoqiang Ji, and R. Longman. Two new stable inverses of discrete time systems, Astrodynamics Specialist Conference, AAS/American Institute of Aeronautics and Astronautics (AIAA), vol. 171(1), 2020, pp. 4137-4143.