优德官网 in the AIR

概述
日期
2023年05月18日
09:00 - 10:30
所在
运动行、Bilibili

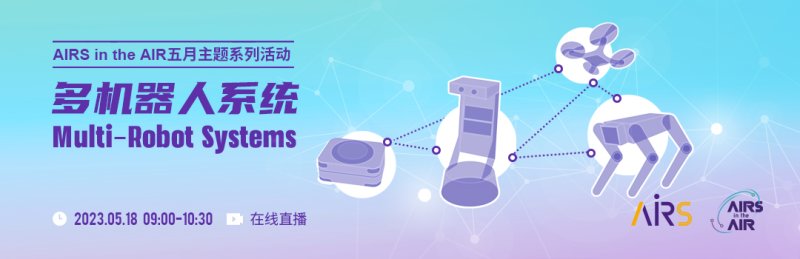
优德官网 in the AIR | 多机械人系统(二)

首页- 优德官网集团(中国)有限公司

多机械人系统由众多自力的机械人个体组成,,,, ,,个体间可自主地协同相助,,,, ,,相比单个机械人具有更高的效率、可扩展性和容错能力,,,, ,,正在改变各行各业应对重大使命的方法,,,, ,,在物流运输、工业生产和情形监测等诸多领域取得了普遍应用。。。。。。

优德官网 in the AIR 五月系列运动约请天下顶级学者围绕“多机械人系统”开展讲座,,,, ,,第二期将约请卡耐基梅隆大学(CMU)Sebastian Scherer 教授和东京大学 Moju Zhao 教授划分分享机械人路径妄想与意图展望,,,, ,,和航行机械人模浚?? ? ?榛杓朴胗τ。。。。。。

Sebastian Scherer 是 CMU 机械人研究所副教授,,,, ,,他的研究重点是在具有挑战性的情形中实现机械人的自主化,,,, ,,曾向导 CMU 团队进入 SubT 挑战赛,,,, ,,在航行机械人的自主化方面告竣多个“首次”突破。。。。。。

Moju Zhao 是东京大学助理教授,,,, ,,他的主要研究偏向是航行机械人的机械设计、建模与控制、运动妄想和基于视觉的识别。。。。。。他主导研究的铰接式航行机械人在国际聚会和期刊上获得了多个奖项,,,, ,,包括2018年 IEEE ICRA 最佳论文奖。。。。。。

通过Bilibili(http://live.bilibili.com/22587709)加入。。。。。。

呼吸新鲜空气,,,, ,,相识前沿科技!优德官网 in the AIR 为 优德官网 重磅推出的系列运动,,,, ,,与您一起探索人工智能与机械人领域的前沿手艺、工业应用、生长趋势。。。。。。

  • 首页- 优德官网集团(中国)有限公司
    林天麟
    优德官网 智能机械人中心主任、香港中文大学(深圳)助理教授
    执行主席
  • 首页- 优德官网集团(中国)有限公司
    张添威
    优德官网 智能机械人中心副研究员
    主持人
  • 首页- 优德官网集团(中国)有限公司
    Sebastian Scherer
    卡耐基梅隆大学机械人研究所副教授
    Informative Path Planning, Exploration, and Intent Prediction

    Sebastian Scherer is an Associate Research Professor at the Robotics Institute (RI) at Carnegie Mellon University (CMU). His research focuses on enabling autonomy in challenging environments and previously led CMU’s entry to the SubT challenge. He and his team have shown several firsts for autonomy for flying robots and off-road driving. Dr. Scherer received his B.S. in Computer Science, M.S. and Ph.D. in Robotics from CMU in 2004, 2007, and 2010.

    As autonomous agents are able to navigate to more and more difficult and uncertain situations a key challenge becomes on deciding where to move to next especially for teams of agents. This talk will explore various ideas on how to tackle this challenge and present results for search, exploration, intent prediction, and offroad driving.

  • 首页- 优德官网集团(中国)有限公司
    Moju Zhao
    东京大学助理教授
    Modularity in Aerial Robotics and its Applications

    Prof. Moju Zhao is currently an Assistant Professor at The University of Tokyo. He received Doctor Degree from the Department of Mechano-Informatics, The University of Tokyo, 2018. His research interests are mechanical design, modelling and control, motion planning, and vision based recognition in aerial robotics. His main achievement is the articulated aerial robots which have received several awards in conference and journal, including the Best Paper Award in IEEE ICRA 2018.

    During the last decade, research on aerial robots has become significantly active. Among the developments of the platform, several modular designs have been proposed to offer the reconfigurable capability for advanced maneuvering in midair. In this talk, we will present the development of our original modular aerial robots, which involves the methodology of modular design, modelling and control, and motion planning. Furthermore, the unique aerial application, such as snake-like maneuvering and manipulation in midair will be also introduced.


时间 环节 嘉宾与问题

09:00-09:40

主题报告

Sebastian Scherer ,,,, ,, 卡耐基梅隆大学机械人研究所
问题:Informative Path Planning, Exploration, and Intent Prediction  

09:40-10:30

主题报告

Moju Zhao ,,,, ,,东京大学  
问题 :Modularity in Aerial Robotics and its Applications       

视频回首