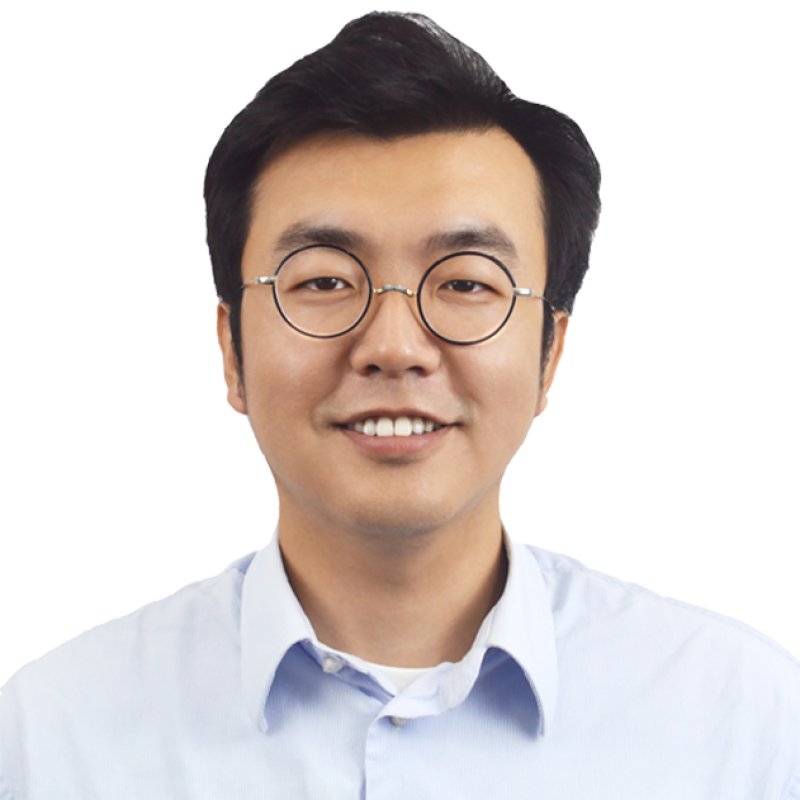
冀晓强教授在美国哥伦比亚大学获得博士学位�,�,�,,,�,�,现任香港中文大学(深圳)助理教授、博士生导师�,�,�,,,�,�,优德官网具身智能中心副主任�,�,�,,,�,�,广东省具身智能机械人立异中心、工程手艺研究中心及工程研究中心副主任�,�,�,,,�,�,中国仿真学会智能物联专委会委员�,�,�,,,�,�,东盟 - 中国人工智能实验室首席科学家。。�。。。
他的研究主要集中在人工智能控制系统�,�,�,,,�,�,主持多项科研及人才项目�,�,�,,,�,�,包括国家自然科学基金数据科学与人工智能前沿探索课题、广东省面上、深圳市重大等项目。。�。。。至今在IEEE Transactions on Automatic Control (TAC)、Automatica、Journal of Field Robotics (JFR)、ACM T-CPS、IEEE/ASME T-Mech、T-ASE、RA-L、CDC、ICRA等顶尖国际期刊及聚会揭晓论文六十余篇�,�,�,,,�,�,1本专著。。�。。。特殊是在非最小相位系统方面�,�,�,,,�,�,是该领域全球规模内学习控制设计的推动者之一。。�。。。他担当包括IEEE-TAC在内的多个顶级期刊及聚会的审稿人、MECC副编辑、Robot Learning青年编委、RCAR等国际聚会领域主席�,�,�,,,�,�,并于近期获得CINT优异论文奖、ISUI最佳论文奖、Wiley中国高孝顺作者奖等。。�。。。
冀教授向导的人工智能控制与决议实验室�,�,�,,,�,�,是一个学科交织平台�,�,�,,,�,�,需要深度融合控制论、人工智能、机械人学、高性能盘算、大数据等基础科学�,�,�,,,�,�,致力于开展人工智能与智能辖档挽域的基础理论与原创性研究。。�。。。
学术领域(最多选择3项):
- 人工智能与机械人
- 盘算机工程
- 电子工程
- 化学
- 数学与应用数学
- 质料学
- 新能源科学与工程
- 物理
小我私家网站:
https://cnd-lab.github.io/
专著:
· Xiaoqiang Ji, Y. Chen, Y. Chen, and S. Liu. Embodied�Intelligent Dexterous Hand Manipulation (in Chinese), PHEI 电子工业出书社.
Research Paper: (*Correspondence author)
- Xiaoqiang Ji*, Y. Dou, S. Zhu and Y. Xu. Unified feedforward control framework for disturbed nonminimum phase systems: the Koopman-type inverse operator approach. IEEE Transactions on Automatic Control, vol. 71, no. 7, pp. 4858-4864, July 2026.
- Z. Lin, Z.Wei, Y.Zhong, N. Ding Y.Zhao and Xiaoqiang Ji*. ALICE: Autonomous lifelong intelligence framework for cross-embodiment via continuous internal states feedback mechanism. Future Generation Computer Systems, vol 186, Jan. 2027, 108730.
- H.Yu, S.Zhu, Z.Sun and Xiaoqiang Ji*. Online stable inversion of non-minimum phase systems with guaranteed stability via terminal-constrained MPC. IEEE 65th Conference on Decision and Control (CDC), 2026, accepted.
- S. Zhu, Xiaoqiang Ji*, R. Longman, and Y. Xu. Presicion tracking for non-minimum phase LPTV systems via a lifted time stable inversion. IEEE Transactions on Automatic Control, 10.1109, pp. 1-8, 2025.
- H.Wan, Y.Zhang, J.Wang, D.Wu, M.Li, X.Chen, Y.Deng, Y.Huang, Z.Sun, L. Zhang and Xiaoqiang Ji*. Toward universal embodied planning in scalable heterogeneous collaboration and control, Journal of Field Robotics (JFR), 1556-4959, 2025.
- Xiaoqiang Ji*, S. Zhu, Y. Xu, and R. Longman. Lifted time stable inversion based feedforward control for linear non-minimum phase systems, Automatica, vol. 171, pp. 111979, 2025.
- H.Wan, J.Cheng, Y.Deng, D.Wu, Y.Chen, Z.Lin, J.Liu, J.Yu and Xiaoqiang Ji*. Towards physics aware embodied control with grapth based object-centric learning, ACM Transactions on Cyber-Physical Systems, Sep 2025.
- H.Wan, Y.Chen, Y.Deng, Z.Wei, D.Li, Z.Lin, D.Wu, J.Cheng, and Xiaoqiang Ji*. EmbodiedAgent: A scalable hierarchical approach to overcome practical challenge in multi-robot control, 2025 IEEE/RSJ Internaitonal Conference on Intelligent Robots and Systems (IROS), accepted, 2025.
- S.Zhu, Xiaoqiang Ji*, R. Longman, and Y. Xu. Lifted time stable inversion based high precision feedforward control for non-minimum phase systems, IEEE 63rd Conference on Decision and Control (CDC), December 16-19, 2024.
- Xiaoqiang Ji, X.Zhang, S.Zhu, F.Deng and B.Zhu. Data-driven adaptive consensus control for heterogeneous nonlinear multi-agent systems using online reinforcement learning, Neurocomputing, Vol. 596, 127818, 2024.
- J.Li, C.Zhao, Xiaoqiang Ji*, M.Li, G.Lu, Y.Xu, and D.Zhang. Multi-view instance attention fusion network for classification, Information Fusion, Vol. 101, 101974, 2024.
- K.Xue, Xiaoqiang Ji*, D.Qu, Y.Peng and H.Qian*. Oboat: An agile omnidirectional robotic platform for unmanned surface vehicle tasks, IEEE/ASME Transactions on Mechatronics (T-Mech), vol.28, no.5, pp.2413-2424, Oct. 2023.
- S. Zhu, Y. Wang, B. Zhu, and Xiaoqiang Ji*. Tracking error boundary of novel stable inversion based feedforward control for a class of non-minimum phase systems, CINT, vol 1714, Springer, 2023. [ Excellent Paper Award]
- K.Xue, C.Ren, Xiaoqiang Ji*, and H. Qian*. Design, modeling and implementation of a projectile-based mechanism for USVs charging tacks, IEEE Robotics and Automation Letters (RA-L),vol. 8, no. 1, pp. 360-367, Jan. 2023.
- K.Xue, J. Liu, N. Xiao, Xiaoqiang Ji*, and H. Qian*. A bio-inspired simultaneous surface and underwater risk assessment method based on stereo vision for USVs in nearshore clean waters, IEEE Robotics and Automation Letters (RA-L), 2022.
- Xiaoqiang Ji*, and R. Longman. Two new stable inverses of discrete time systems, Astrodynamics Specialist Conference, AAS/American Institute of Aeronautics and Astronautics (AIAA), vol. 171(1), 2020, pp. 4137-4143.